
2K & LSR Molding for Robot Hands & Grippers
A robot hand needs a hard skeleton and a soft grip. Multi-component molding builds both into one part — rigid finger structure, soft tactile pad, molded together in a single process.
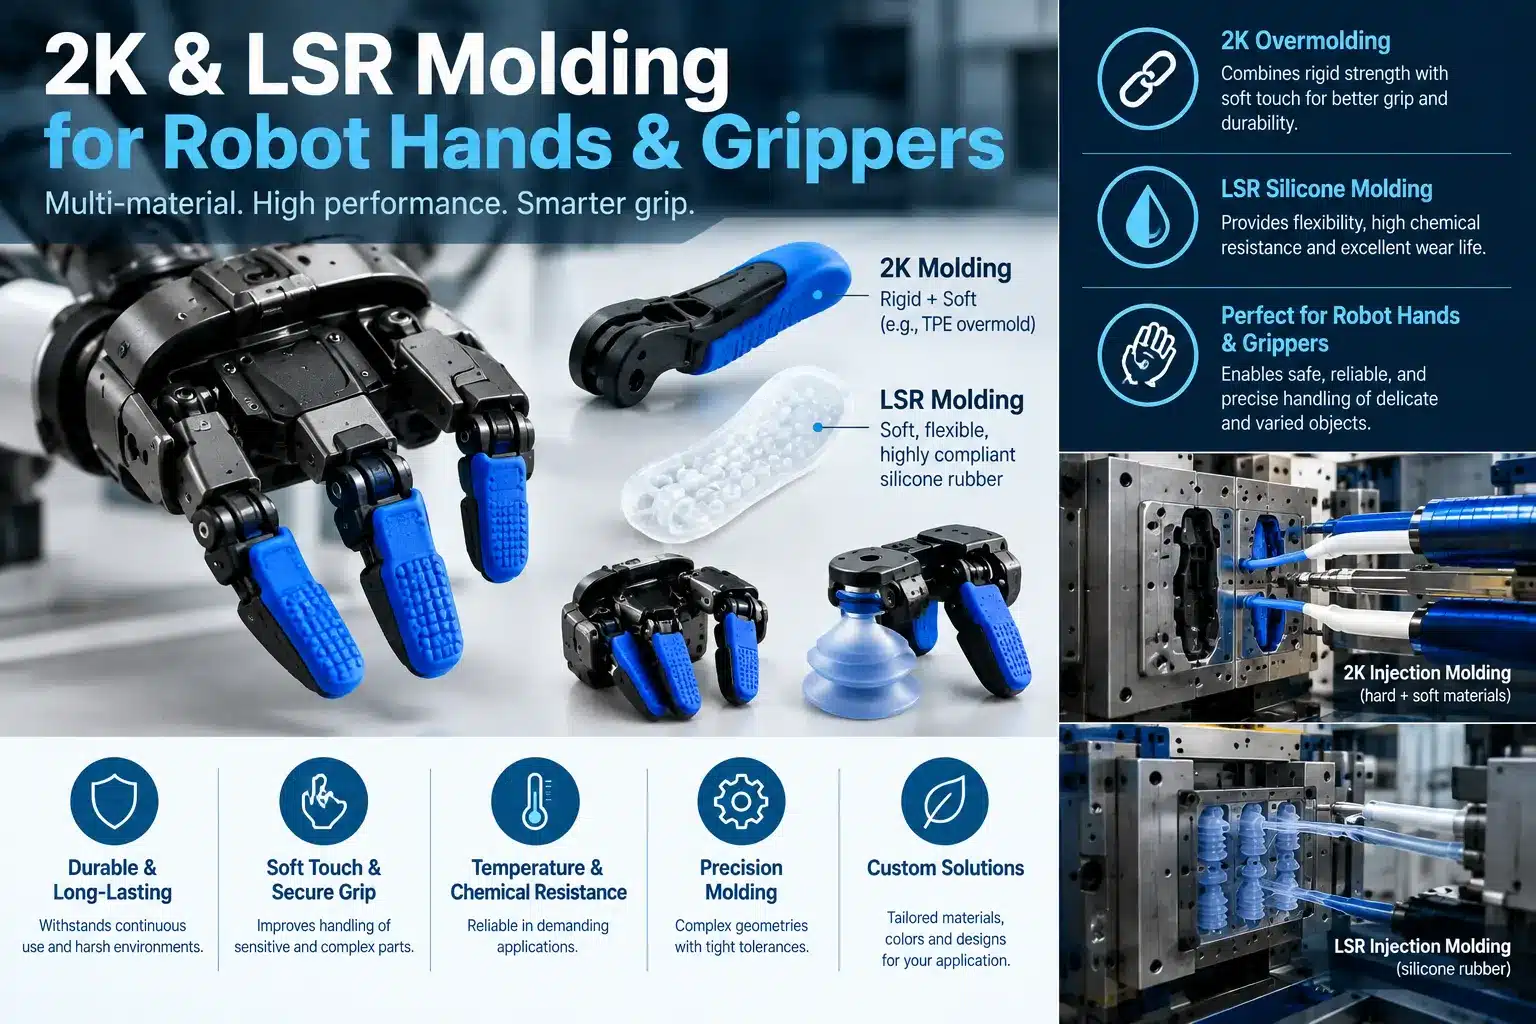
This guide explains 2K molding and LSR overmolding for dexterous hands and grippers: what each is, how they differ, the material pairs that bond, and the adhesion pitfalls that sink a program. It expands the robotics & AI hardware overview.
Hard-soft molding for robot hands in brief:
- 2K molding: rigid substrate and soft material molded in one machine, one cycle, with cavity-to-cavity alignment.
- LSR overmolding: liquid silicone molded over an already-finished part or metal substrate.
- Where it goes: fingertips, grip pads, flexible joints, tactile sensor skins.
- The hard part: getting the soft material to bond reliably to the rigid one.
Why robot hands need hard and soft together
Grip is a contradiction. The finger must be stiff enough to hold structure and transmit force. The contact surface must be soft enough to conform, cushion, and grip without crushing.
Bolting a rubber pad onto a plastic finger is the old way. It adds parts, adds an assembly step, and the pad peels off. Molding the soft material directly onto the hard structure removes all three problems.
2K molding vs LSR overmolding
Both make hard-soft parts. The difference is how many steps and which soft material.
| 2K (two-shot) molding | LSR overmolding | |
|---|---|---|
| Process | Both materials molded in one machine, one cycle | Soft material molded over a finished substrate |
| Alignment | Cavity-to-cavity in the tool — very precise | Substrate placed into the LSR cavity, often by robot |
| Soft material | TPU / TPE, or LSR on 2K-capable machines | LSR (liquid silicone rubber) |
| Bond | Mechanical, thermal, chemical, or combined | Chemical or mechanical to plastic, metal, glass |
| Best for | High volume, tight registration, one-cycle output | Metal substrates, silicone-specific properties |
Note: LSR is a thermoset silicone, not a thermoplastic. It can be run in a 2K cell on the right machine, or as a separate overmold step. Which route fits depends on volume, substrate, and the soft material you need.
Soft materials: TPU/TPE vs LSR
TPU / TPE
Thermoplastic elastomers are easy to process and bond well to many rigid thermoplastics. They suit grip pads and soft joints where the environment is mild. Good default for cost and simplicity.
LSR (liquid silicone rubber)
LSR wins where TPE struggles. It handles heat, stays flexible at extreme cold, resists chemicals, and has natural lubricity. It comes in a wide hardness range, from roughly 10 to 70 Shore A. That range lets you tune a fingertip soft and a joint firmer.
The real challenge: adhesion
A hard-soft part is only as good as the bond between the layers. This is where programs fail. Soft-on-hard adhesion needs deliberate engineering.
Two levers control the bond: material pairing and mechanical grip.
- Pair for chemistry. Match a self-adhering soft grade to the specific rigid substrate. The wrong pair peels no matter what else you do.
- Add mechanical grip. Through-holes, undercuts, and grooves in the hard part let the soft material key in physically, backing up the chemical bond.
Design points for dexterous hands
- Substrate first. Pick the rigid resin — PA12, POM, or PC — for structure and joint wear, then choose a soft grade that bonds to it.
- Watch thermal mismatch. Hard and soft materials expand and cure differently. Poorly managed, that causes weak adhesion or distortion.
- Mold complexity is real. Multi-component tools cost more and need precise alignment. Plan tooling budget accordingly.
- Place the soft material precisely. Molding puts the pad exactly where grip is needed — no more, no less.
Substrate + soft pairings
| Hard substrate | Soft partner | Fits |
|---|---|---|
| PA12 / PA (nylon) | TPU | Durable finger structure with grip pad |
| POM | TPE | Low-friction joint with soft contact |
| PC / PC-ABS | Self-adhering LSR | Tough base with heat/chemical-resistant skin |
| Metal (steel) | LSR (overmold) | Metal joint with silicone contact surface |
Designing a gripper or dexterous hand?
Send your finger or fingertip design. We will advise the substrate, the bondable soft grade, and whether 2K or LSR overmolding fits your volume — then quote the tool and parts.
Upload your design for a quoteRelated guides
Humanoid robot molded parts overview →
Insert molding for robotics →
Robot plastic material selection guide →
Frequently asked questions
What is 2K molding for robot hands?
Two-component molding combines a rigid substrate and a soft material in one machine and one cycle, with cavity-to-cavity alignment. It produces a hard finger structure with a soft grip as a single part.
What is the difference between 2K molding and LSR overmolding?
In 2K molding both materials are molded together in one process. In LSR overmolding, liquid silicone is molded over an already-finished plastic or metal substrate as a second step.
Should a robot gripper use TPE or LSR?
TPE is simpler and cheaper and bonds well to many plastics. LSR is chosen for heat resistance, extreme cold flexibility, chemical resistance, and a wide hardness range from about 10 to 70 Shore A.
Why does the soft grip peel off a robot finger?
Poor adhesion between the soft and hard layers. Fix it by pairing a self-adhering soft grade to the specific substrate, and adding mechanical grip such as through-holes and undercuts in the hard part.
Can silicone be molded onto metal robot parts?
Yes. LSR overmolding can bond silicone to a metal substrate such as steel. This suits a metal joint that needs a silicone contact surface for grip, sealing, or cushioning.
Bottom line. A robot hand is a hard-soft molding problem. 2K molding builds structure and grip in one cycle; LSR overmolding adds silicone’s heat and chemical resistance, even onto metal. The whole design lives or dies on adhesion — the right material pair plus mechanical grip. Send a fingertip or gripper design and we will spec the substrate, the bondable soft grade, and the process that fits your volume.

